
When: Thursday, 24 September, 10:00 am AEST
Where: This seminar will be presented at the ACFR seminar area, J04, Level 2 (Rose St Building) and partially online via Zoom. RSVP
Title: An Adaptive Approach to Human-Machine Collaborative 3D Perception
Speaker: Cedric Van Heck
Abstract:
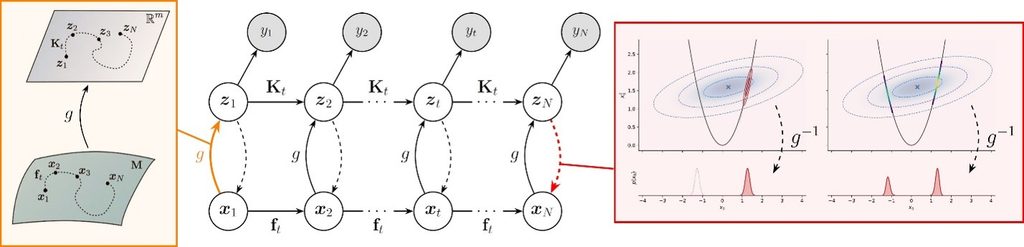
Koopman operator theory promises something attractive: lift a nonlinear system into a space of observables where its dynamics become linear, enabling the use of standard and well-established linear methods for prediction, estimation and control. One method that benefits from this is the Kalman Filter for state estimation. However, the lift inherently creates constraints that existing Koopman Kalman filters silently violate. The lifted state cannot be an arbitrary vector in the high-dimensional lifted space, as its components are algebraically tied to one another and live on a manifold. In our work, we investigate how this manifold information can be incorporated into a Koopman-based Kalman filter.
First, methods for projecting the belief onto the manifold are investigated. However, the result is ultimately a local approximation. Alternatively, we propose a belief representation that is on-manifold by design. This approach avoids the need for projection or correction, remains valid globally, and naturally allows for multimodal posterior distributions.
Bio:
Cedric Van Heck is a PhD candidate in the Energy & Systems Lab at Ghent University, supervised by G. Crevecoeur and A. Coene. He is currently a visiting researcher at the Australian Centre for Robotics, University of Sydney, under the supervision of Pieter van Goor. He received the M.Sc. degree in electrical and mechanical engineering from Ghent University, Ghent, Belgium, in 2021.