
When: Thursday, 8 October, 1:00 pm AEST
Where: This seminar will be presented at the ACFR seminar area, J04, Level 2 (Rose St Building) and partially online via Zoom. RSVP
Title: Linear-Complexity Global Attention for Multi-Scale Iterative Stereo Matching
Speaker: Yiran Wang
Abstract:
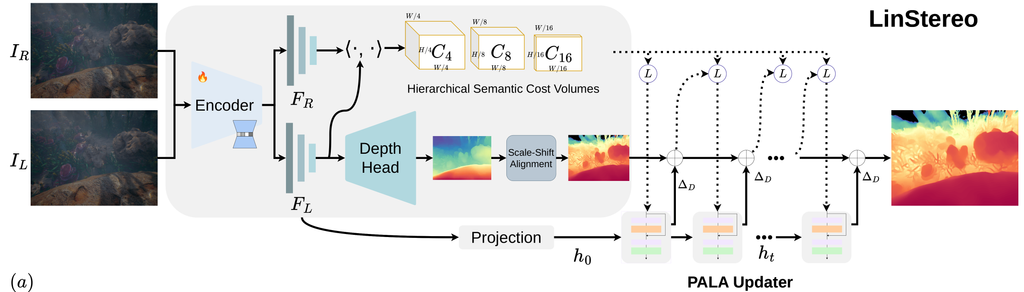
Modern stereo systems increasingly rely on vision foundation models, but their iterative decoders often discard multi-scale information, start from an uninformed disparity estimate, and propagate context only locally. LinStereo addresses this mismatch with a decoder centered on PALA and built on a frozen Depth Anything V3 backbone. Position-Aware Linear Attention (PALA) replaces local recurrent updates with global spatial aggregation whose attention cost grows linearly with the number of image tokens. Hierarchical Semantic Cost Volumes preserve matching evidence at three feature scales, while Depth Prior Initialization aligns monocular inverse depth to sparse stereo matches to provide a geometric warm start. The stereo decoder is trained only on SceneFlow and evaluated without target-domain fine-tuning. LinStereo remains competitive on standard benchmarks and transfers strongly underwater, reducing AbsRel by 28% on TartanAir-UW relative to FoundationStereo and by 26% on the real SQUID dataset relative to IGEV++. The talk examines the architecture, attention formulation, ablations, and computational tradeoffs.
Bio:
Yiran Wang is a PhD candidate at the Australian Centre for Robotics (ACFR) under the School of Aerospace, Mechanical and Mechatronic Engineering at the University of Sydney. His supervisor is Dr. Viorela Ila, and co-supervised by Dr. Gideon Billings.
Yiran’s research focuses on underwater perception for autonomous manipulation, with particular interests in stereo depth estimation, and grasp prediction. Yiran is the first and corresponding author of LinStereo, accepted at ECCV 2026.