
When: Thursday, 12 November, 1:00 pm AEDT
Where: This seminar will be presented at the ACFR seminar area, J04, Level 2 (Rose St Building) and partially online via Zoom. RSVP
Title: Learning methods for Inverse Kinematics and Motion Planning
Speaker: Michael Somerfield
Abstract:
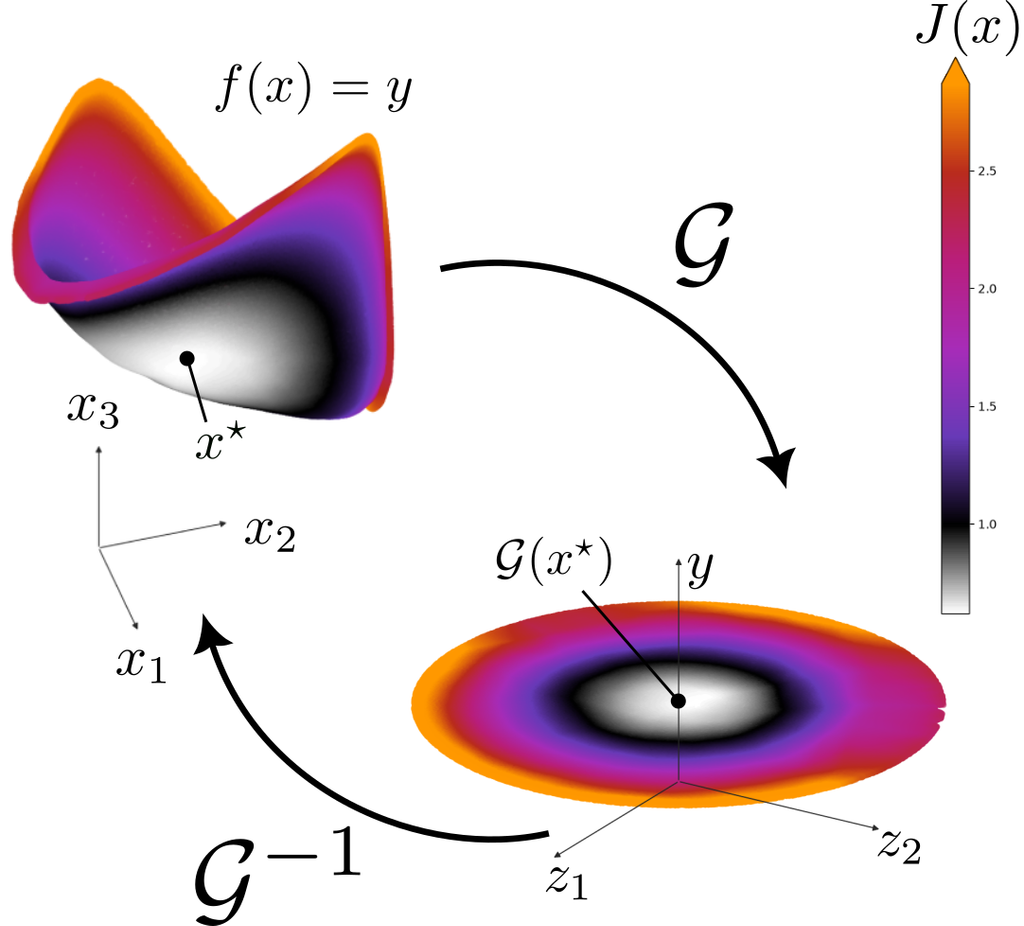
Inverse problems are ubiquitous throughout robotics and many other fields, where a particular output may be given by different unique inputs. A classic example in robotics is forward kinematics for a redundant manipulator, where there may be many different joint angles which achieve a desired end-effector location. When we invert this and start thinking about inverse kinematics, and the problem becomes one where we need to choose one from many potential solutions.
In the first part of this talk I discuss my most recent publication, Learned Optimal Inverse Kinematics, where we utilise invertible neural networks for finding optimal solutions to these inverse problems. This method also allows for sampling for solutions with an upper bounded cost, and smooth paths in the latent space.
In the second part, I discuss some of my current work on manifold learning, with applications to motion planning.
Bio:
Michael graduated from Queensland University of Technology with a Bachelors of Engineering (Mechatronics) in 2019. He then worked for a robotics start-up (Universal Field Robots) for four years before returning to university for a PhD. He has worked on all sorts of robots in all kinds of environments, from multi-ton autonomous excavators in underground mines, autonomous driving in the deserts of Coober Pedy, to legged robots at UQ and now whatever he can get his hands on at ACFR.